Series Quick-Reference Overview
A handy visual quick-reference overview of the series, covering all the key info you need at a glance.
At a glance! (Don’t look with both eyes, okay? >0<)
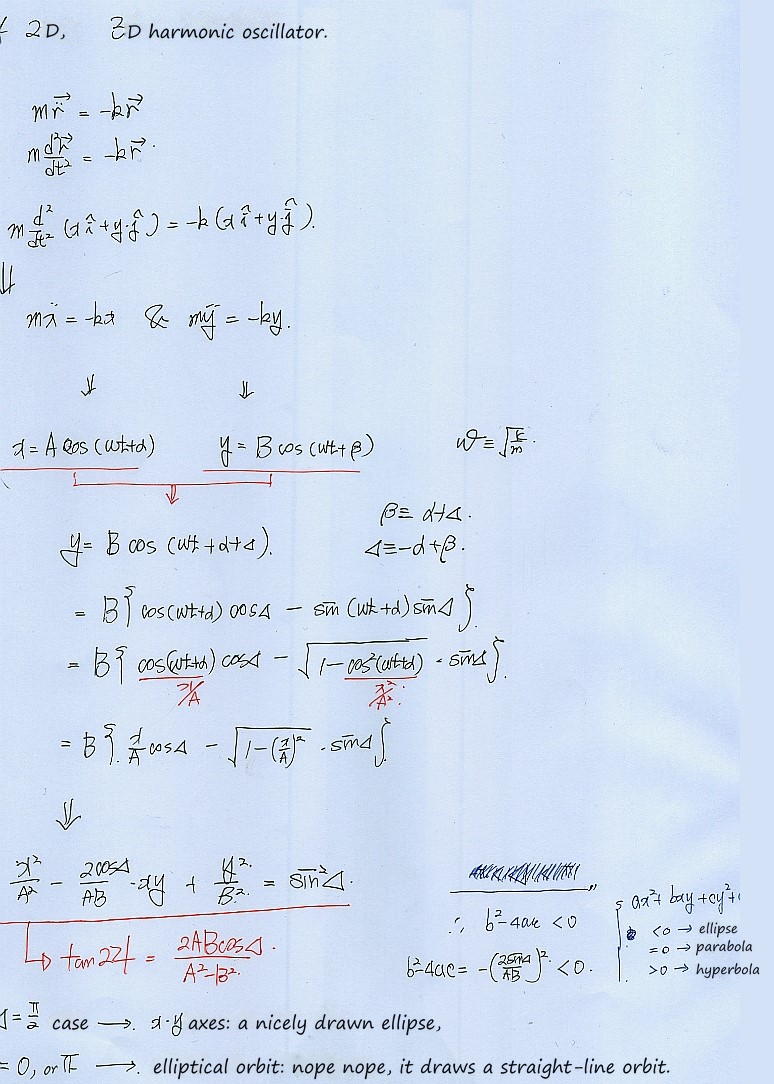
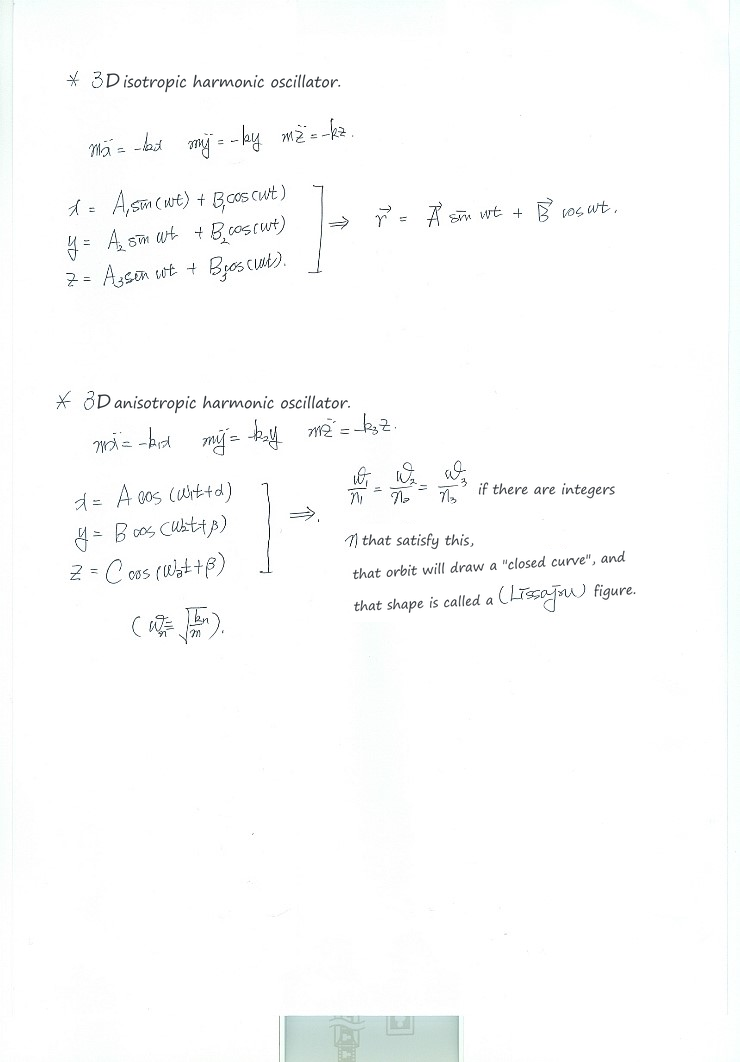
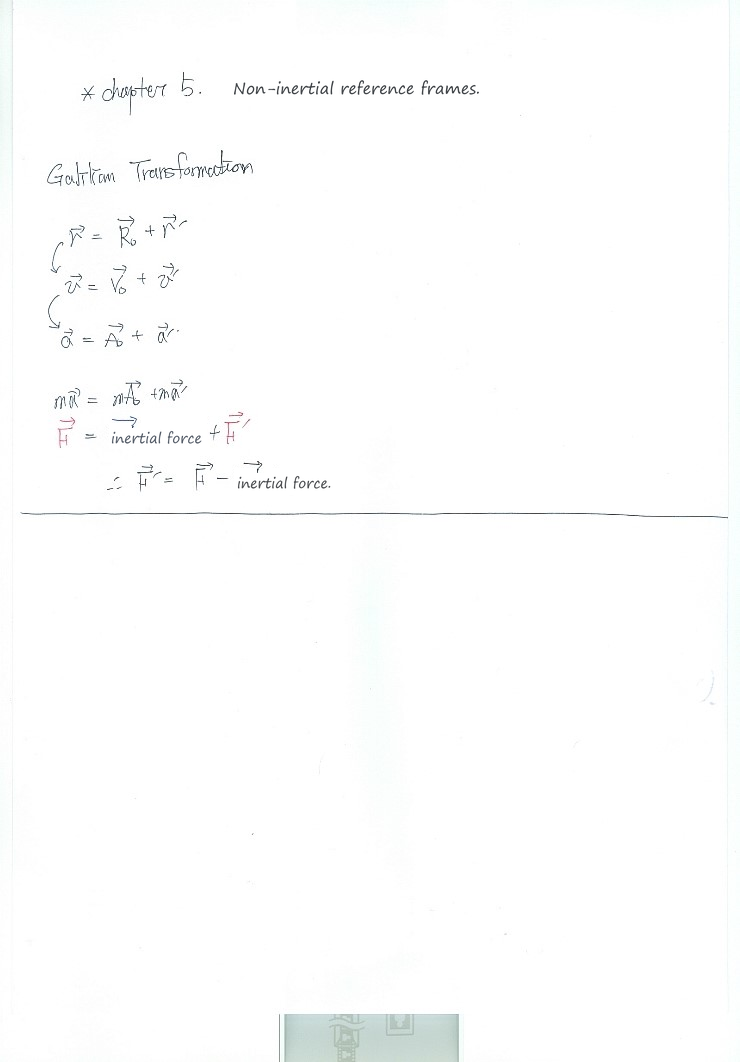
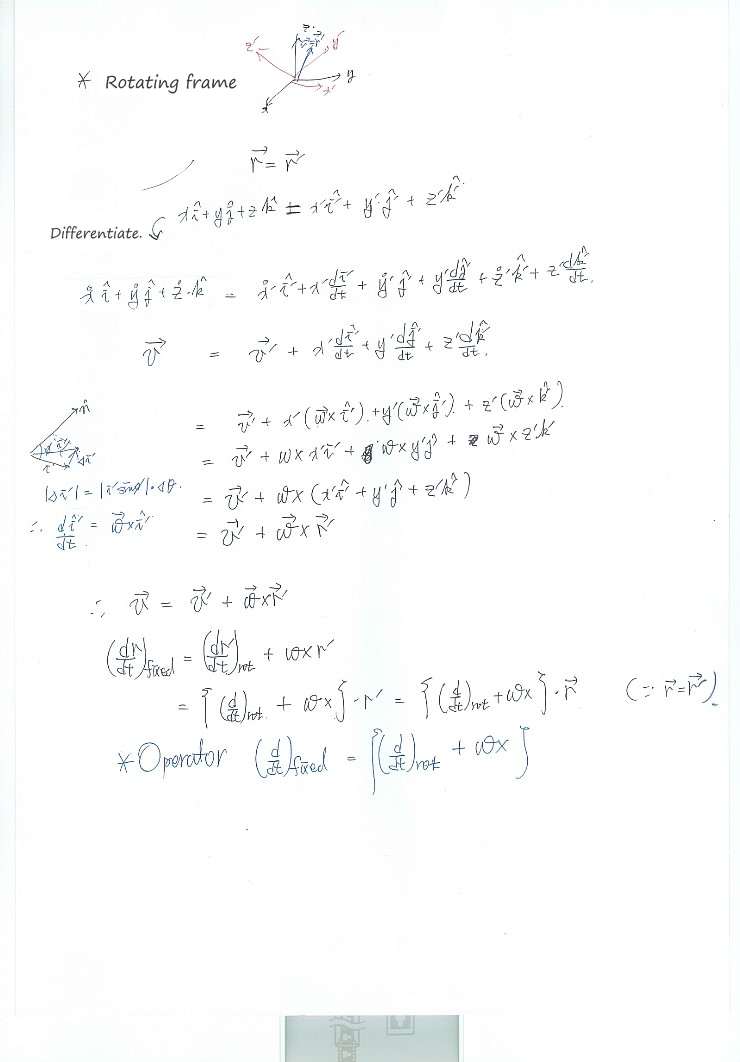
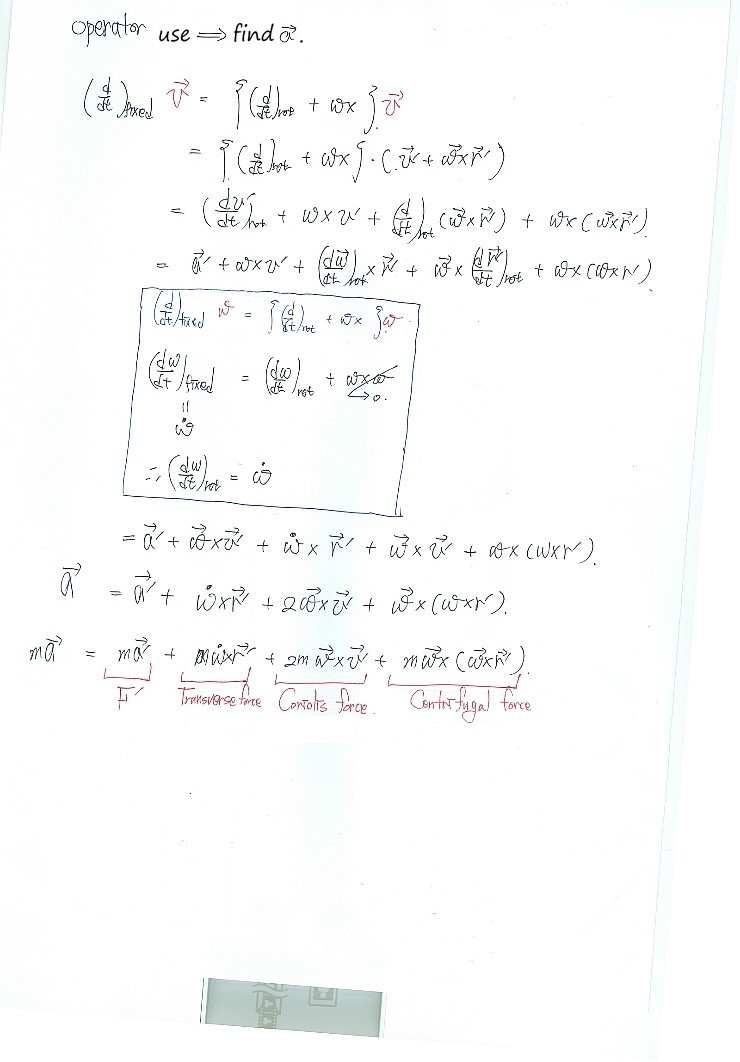
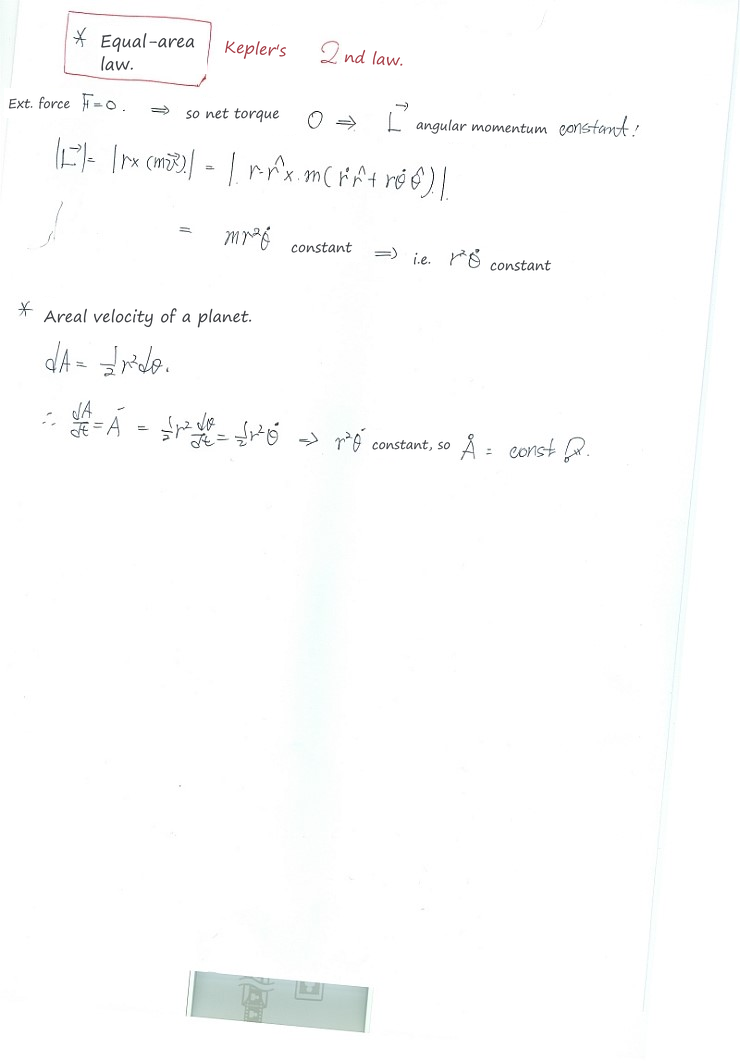
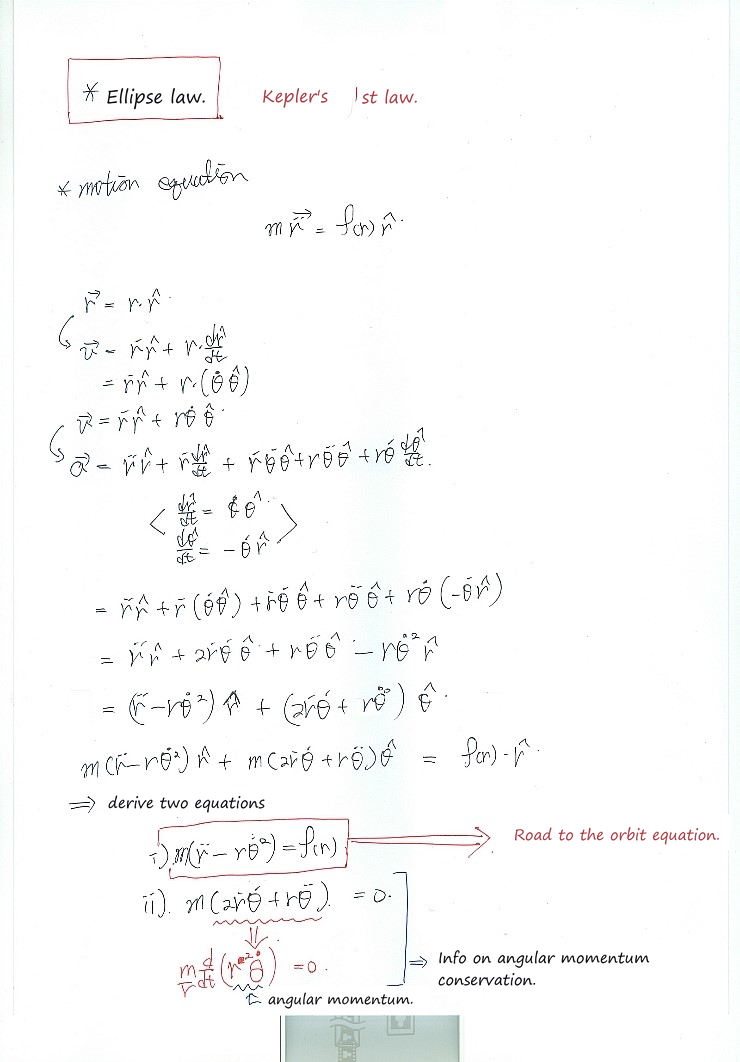
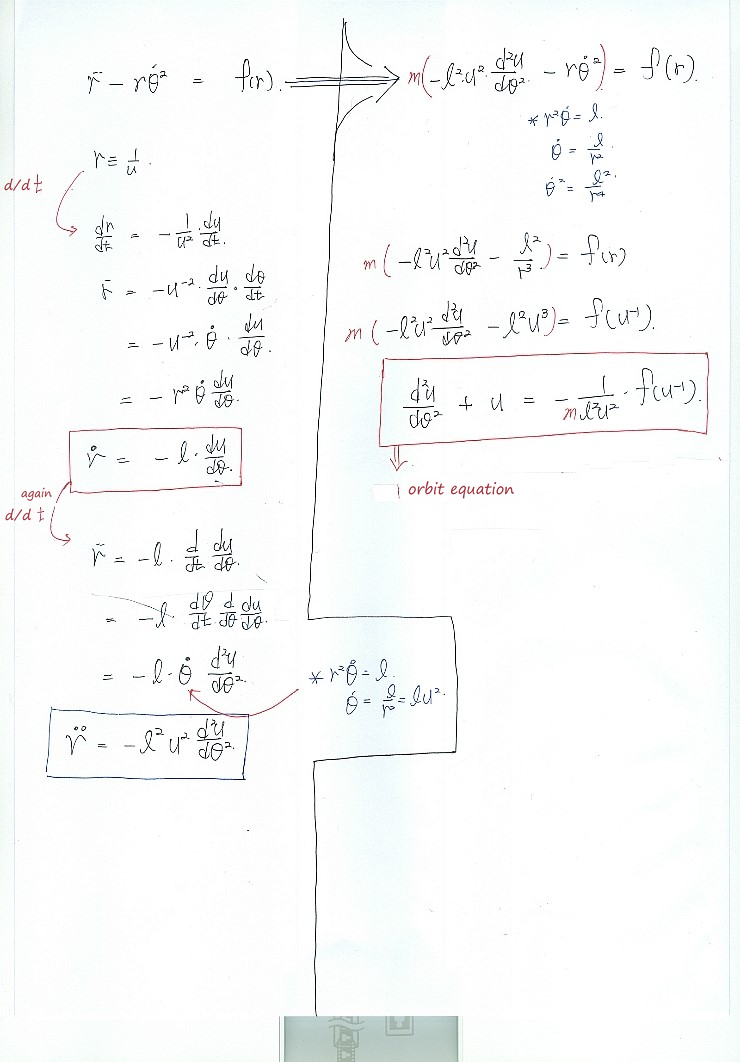
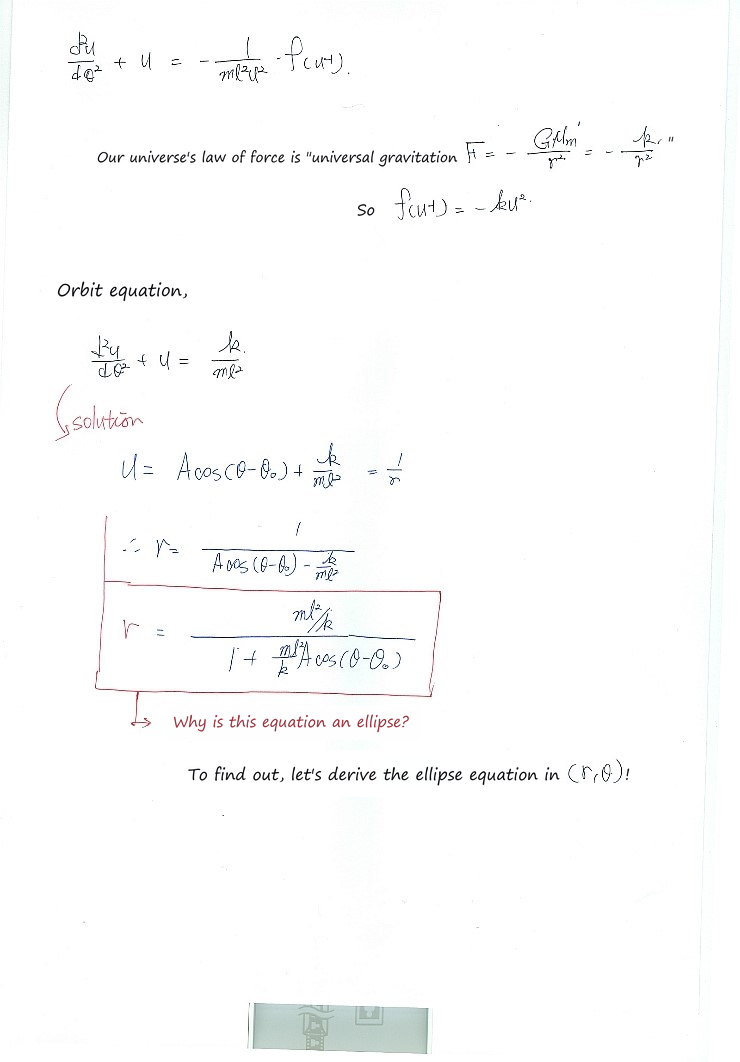
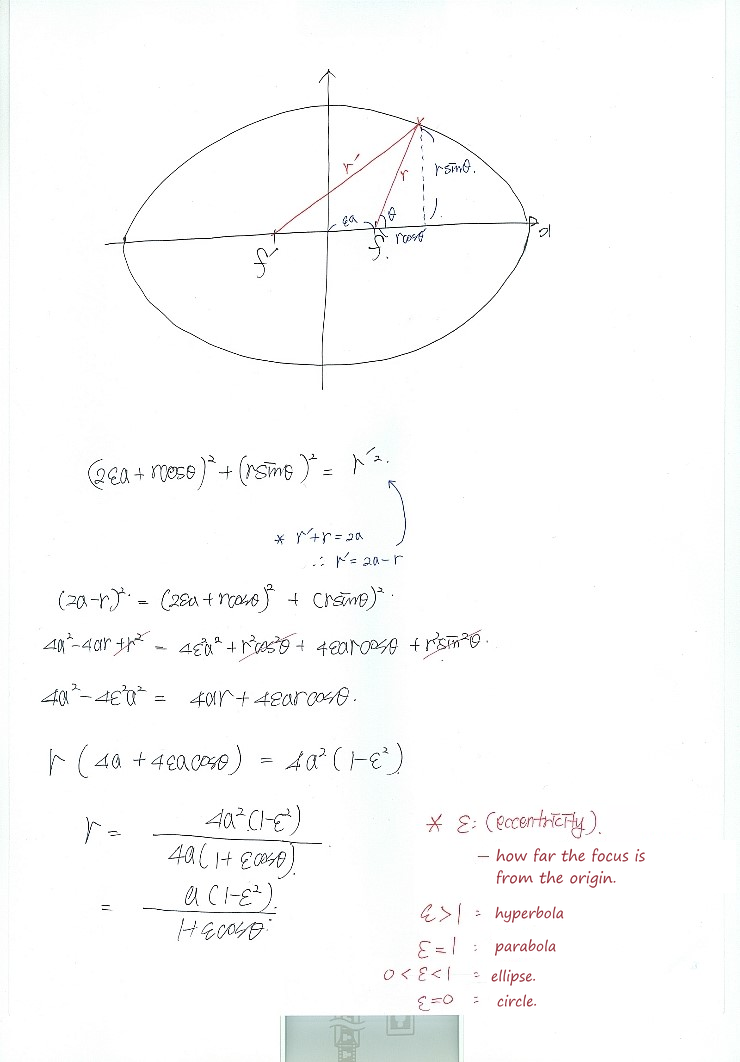
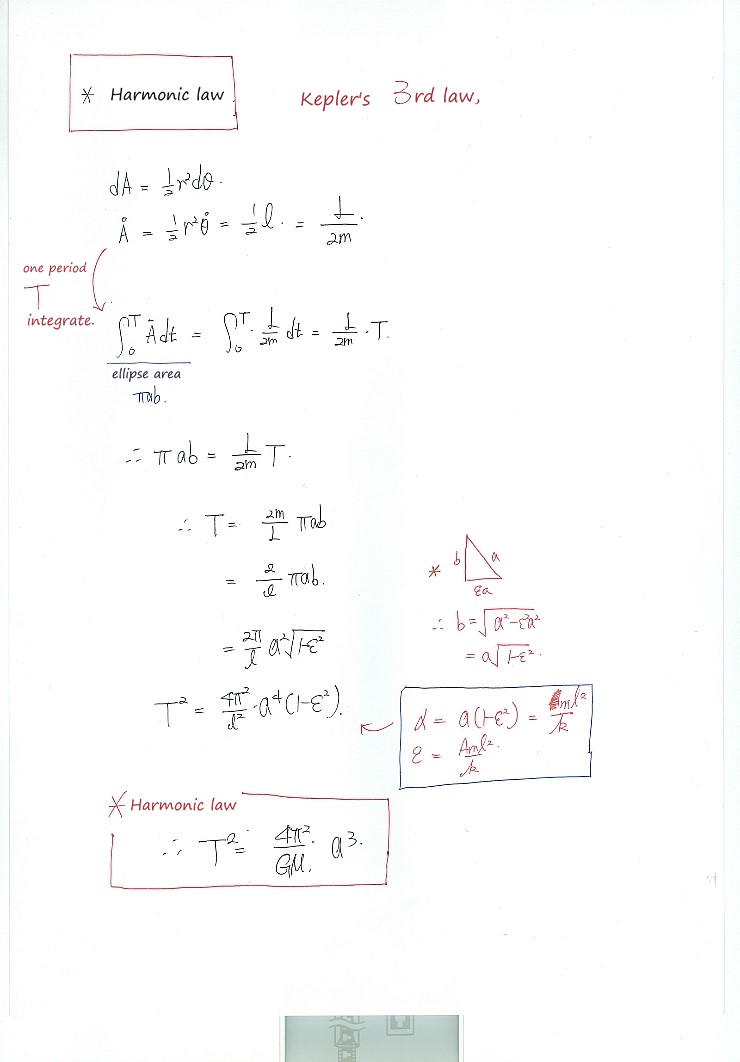
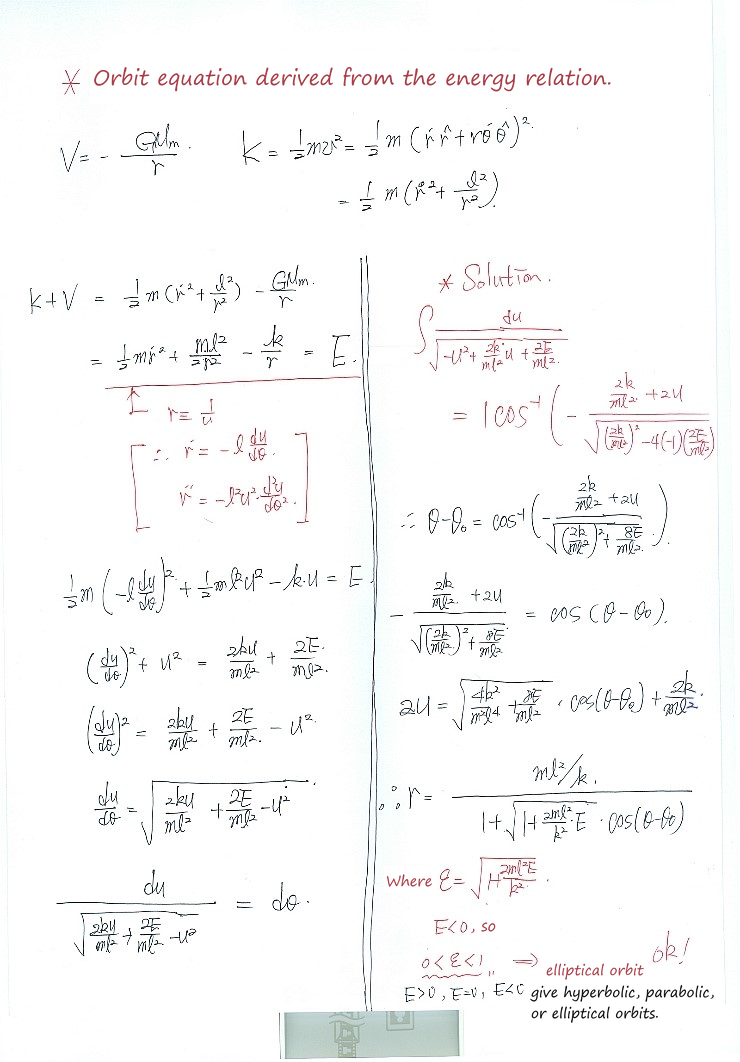
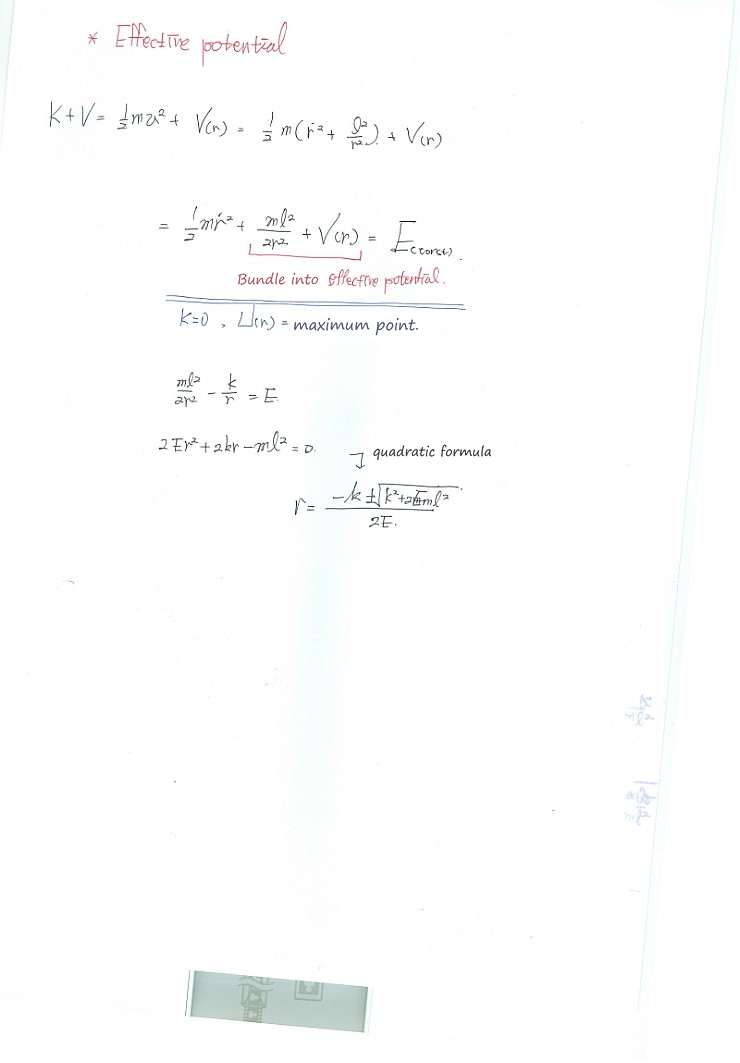
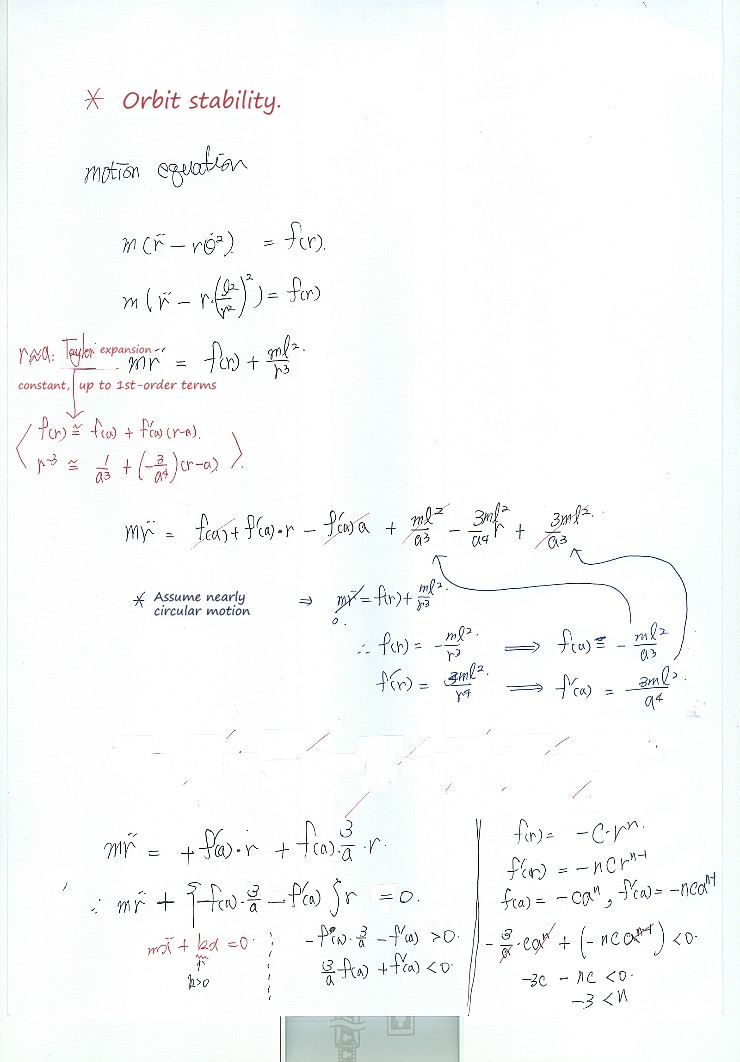
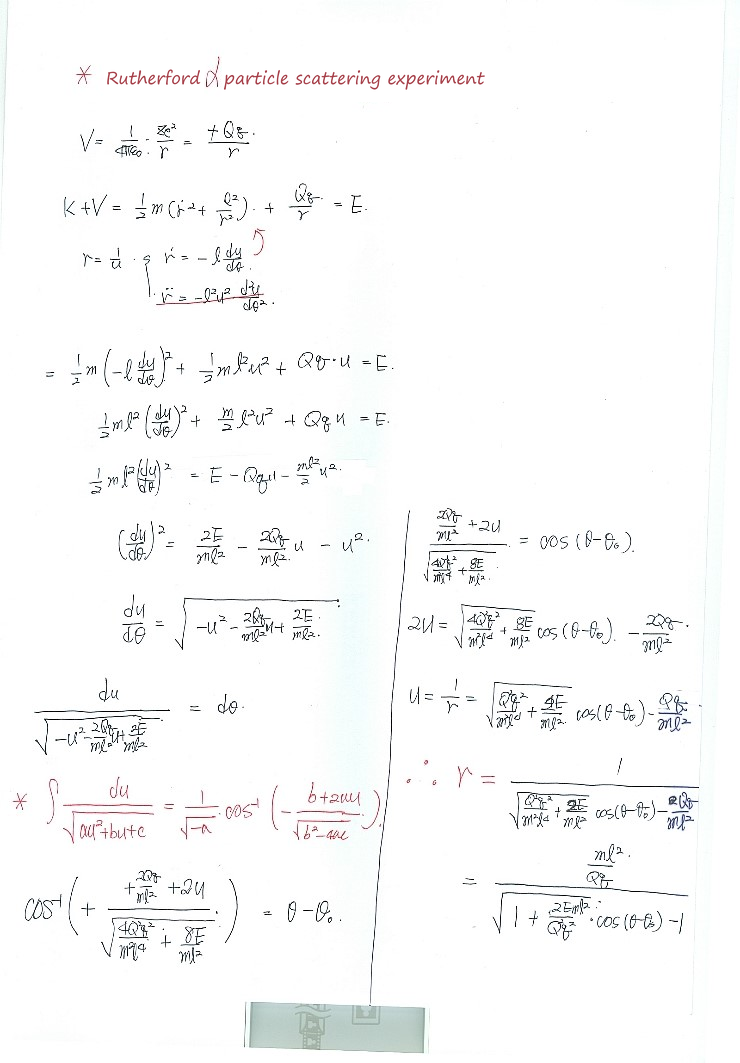
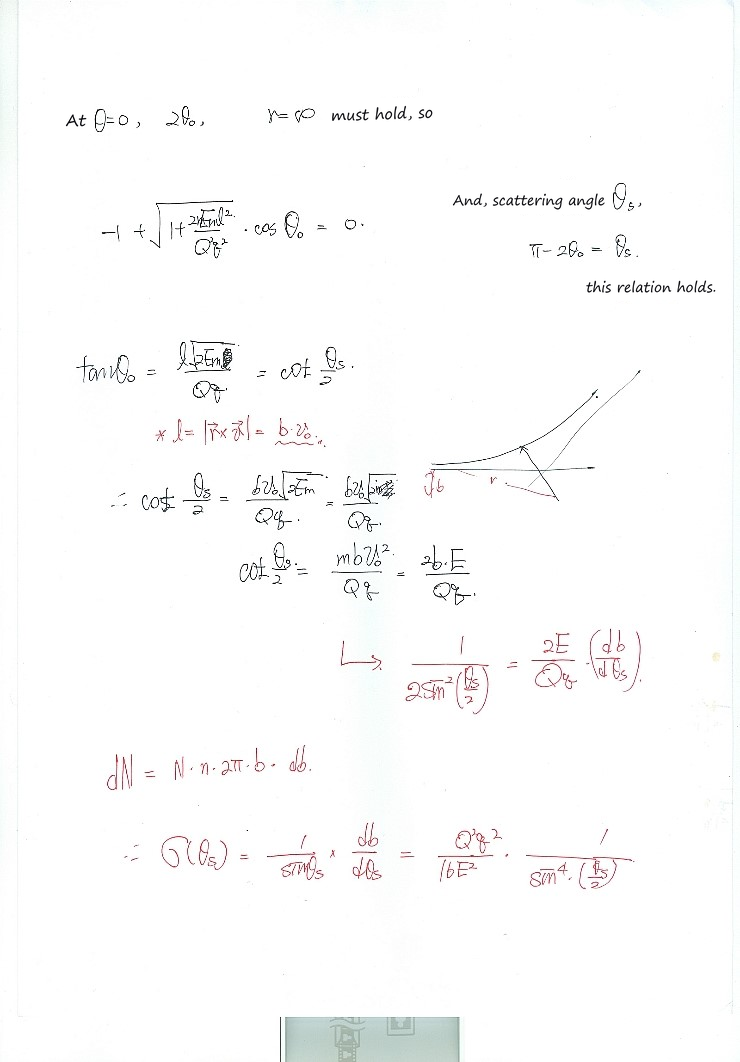
Heads-up. The figures here are the original notes, slips and all. A few things to watch for:
- In the anisotropic 3D oscillator, $z$ has its own phase: $z = C\cos(\omega_3 t + \gamma)$; the picture reuses $\beta$ from $y$.
- In the rotating-frame equation, the three braced terms stand on the side of $m\vec a$; the transverse, Coriolis and centrifugal forces felt in the rotating frame are their negatives: $-m\dot{\vec\omega}\times\vec{r}'$, $-2m\vec\omega\times\vec{v}'$ and $-m\vec\omega\times(\vec\omega\times\vec{r}')$.
- In the equal-area law, the external force is not zero: it is central, so the torque $\vec r\times\vec F$ is zero and $\vec L$ is constant.
- In the orbit-equation derivation, the first equation needs its $m$: $m(\ddot r - r\dot\theta^2) = f(r)$.
- In the inverse-square solution, $r = \frac{1}{A\cos(\theta-\theta_0) + \frac{k}{ml^2}}$, with a plus sign; the boxed formula under it is right.
- In the two energy-method derivations (the orbit and the Rutherford scattering), the integral table has a sign slip: for $a \lt 0$, $\int\frac{du}{\sqrt{au^2+bu+c}} = \frac{1}{\sqrt{-a}}\cos^{-1}\frac{b+2au}{\sqrt{b^2-4ac}}$ plus a constant, and with $a = -1$ the numerator is $b - 2u$. The orbit equations that follow are right.
- In the orbit-stability notes, $\dot\theta = \frac{l}{r^2}$, so $r\dot\theta^2 = \frac{l^2}{r^3}$; the circular-orbit condition gives only $f(a) = -\frac{ml^2}{a^3}$, not $f'(a) = \frac{3ml^2}{a^4}$; and the last equation is for the displacement $x = r - a$: $m\ddot x - \left[f'(a) + \frac{3}{a}f(a)\right]x = 0$. The stability condition $f'(a) + \frac{3}{a}f(a) \lt 0$ is right.
- In the Rutherford derivation, half of $\sqrt{\frac{4Q^2q^2}{m^2l^4} + \frac{8E}{ml^2}}$ is $\sqrt{\frac{Q^2q^2}{m^2l^4} + \frac{2E}{ml^2}}$; the picture writes $4E$ there, and the next line has $2E$.
- In the cross-section notes, differentiating $\cot\frac{\theta_s}{2} = \frac{2E}{Qq}b$ gives $\frac{1}{2\sin^2(\theta_s/2)} = -\frac{2E}{Qq}\frac{db}{d\theta_s}$, and $\sigma(\theta_s) = \frac{b}{\sin\theta_s}\left|\frac{db}{d\theta_s}\right|$; the final $\frac{Q^2q^2}{16E^2}\frac{1}{\sin^4(\theta_s/2)}$ is right.
Comments
Discussion happens via GitHub Discussions. You'll need a GitHub account to comment.